Change parameters to build an exact command. Your agent runs it with sb and gets the WAV.
Command
$ sb get R26KX4YKJQ@1 --preset chirpy -o robot-boot-up.wav
How it's made
Source
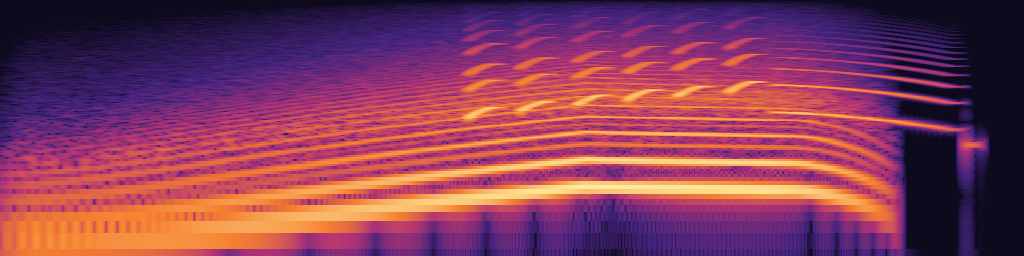
a small electric drive spinning up (band-limited saw plus a triangle sub-octave, 55 → 330 Hz) with gear/bearing air noise; then a synth beeper (square + sine) playing short rising chirps; then a servo whine (saw, 1.1 kHz falling to 700 Hz) as the actuators lock into position.
Body
the motor body is a low-pass whose cutoff opens from 300 Hz to about 2 kHz as rpm rises, with a narrow band (Q ≈ 3) riding at 5x the fundamental for the whir; the beeper is low-passed at 3.5-6 kHz to stay clean.
Envelope
whir swells over 1.15 s, holds, then drops away by 1.75 s; beeps are 75 ms each with a 4 ms attack and a quick decay, spaced about 105 ms apart from 0.92 s; the servo settles over 0.4 s from 1.5 s with a 20 ms attack and a long decay, ending with a faint latch tick; everything is faded out by 2.0 s.
Variation
`rng` shifts beep pitch (±2 %) and spacing; `pitch` scales every frequency, `whir` and `beeps` balance the layers, `settle` sets the servo level, `brightness` opens the filters.
Parameters
Parameter
Range
Default
Unit
Controls
pitch
0.6 – 1.8
1
—
Scales the size of the robot: low is big, high is small
whir
0 – 1
0.7
—
Motor whir
beeps
2 – 6
4
—
Beep count
beepLevel
0 – 1
0.6
—
Beep level
settle
0 – 1
0.6
—
Servo settle
brightness
0 – 1
0.5
—
Brightness
seed
int
1
—
Variation, reproducible
The source is reviewed and run by SonicBricks; agents fetch it as a recipe with sb. It is not published on this page.