Change parameters to build an exact command. Your agent runs it with sb and gets the WAV.
Command
$ sb get 807YMZ9BE1@1 --preset droid -o robot-power-down.wav
How it's made
Source
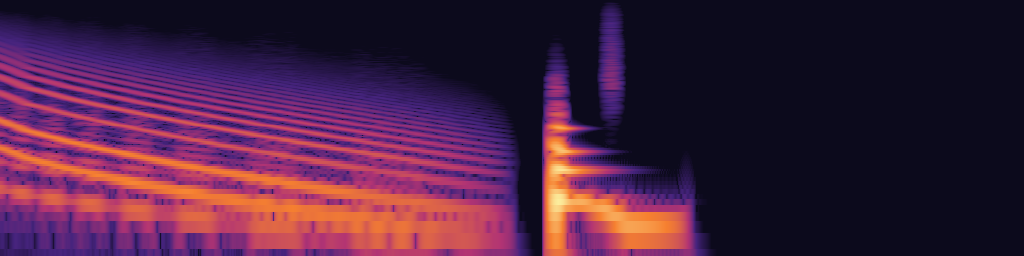
a humanoid machine losing power. Three layers: a drive-electronics whine (saw plus an octave sine) whose pitch collapses as the supply sags, a servo/gear train that spins down (a chopped saw tone plus gear whirr noise), and a final mechanical clunk when the joints lock or the chassis drops onto its latch.
Body
the whine passes a low-pass that tracks 3.5x its pitch, so harmonics vanish first and it ends as a rounded tone. The servo chop is an AM gate at the motor rate (26 Hz slowing to 2.5 Hz) with a 220 Hz tone dropping to 35 Hz. The clunk is a damped metal-housing modal set (95, 210, 340, 610 Hz; 80-250 ms T60) excited by a 12 ms low-passed noise burst, over a 110 to 48 Hz thud and a small high latch tick 90 ms later.
Envelope
10 ms onset ramp, whine and servo sustain for about 60 % of the length and then fade to zero just before the clunk; the pitch curve decelerates so the descent lingers near the bottom. The clunk is instant-attack with a 0.25 s decay and the render ends 0.5 s later.
Variation
`rng` detunes the whine start by up to 2 %, jitters the servo rate, and drives a slow unstable wobble on the whine pitch; `wobble` sets its depth. `pitch` and `length` set start pitch and descent time, `servo` and `clunk` set layer levels. Presets: a heavy mech, a tiny droid, a failing glitchy unit and a silent-servo android with a soft end.
Parameters
Parameter
Range
Default
Unit
Controls
pitch
250 – 1600
700
Hz
Whine pitch
length
0.8 – 2.4
1.4
s
Descent time
servo
0 – 1
0.6
—
Servo
clunk
0 – 1
0.7
—
Final clunk
wobble
0 – 1
0.3
—
Instability
size
0.6 – 1.8
1
—
Chassis size
seed
int
1
—
Variation, reproducible
The source is reviewed and run by SonicBricks; agents fetch it as a recipe with sb. It is not published on this page.