Change parameters to build an exact command. Your agent runs it with sb and gets the WAV.
Command
$ sb get QWW4AZMM62@1 --preset standard -o servo-motor-move.wav
How it's made
Source
a small hobby-grade servo. A DC motor spins a pinion; the first gear stage meshes at 0.8–2.2 kHz and its pulse-like tooth contacts give a harmonic-rich "geared whine". A weaker rotor hum runs well below the mesh rate, plus a thin band of brush and air noise that scales with speed.
Motion
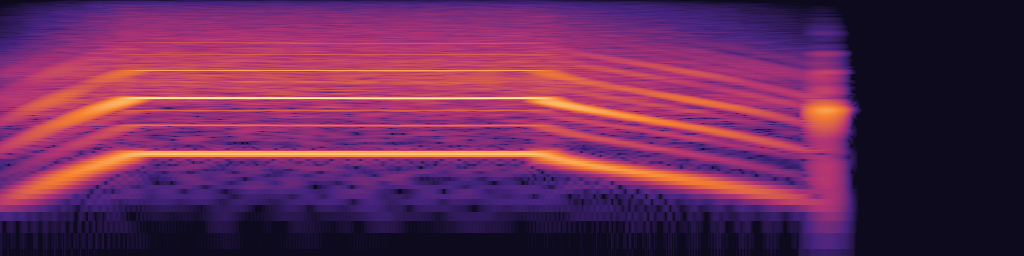
the controller drives a trapezoid speed profile (≈ 0.12 s ramp up, a cruise, ≈ 0.22 s ramp down). Mesh frequency and level follow the speed, so pitch rises, holds with a slight wander, then falls away.
Body
a 3–4 cm plastic case rings as a broad cavity resonance (1.3–2.4 kHz, Q ≈ 2.5) that colours the whine, and a gentle peak near 3.6 kHz adds the plastic edge; nothing below 150 Hz (a small body has no weight).
Events
a 2 ms gear-backlash tick as the motor lets go at the start, and a softer, damped stop click when the output arm reaches the end of travel (modal plastic bar, 20–40 ms).
Variation
`rng` jitters speed wander and click tuning; parameters set distance travelled, whine pitch, gear roughness and case size, and presets cover a micro servo, a standard servo and a slow torquey one.
Parameters
Parameter
Range
Default
Unit
Controls
travel
0 – 1
0.5
—
Travel distance
pitch
0 – 1
0.5
—
Whine pitch
roughness
0 – 1
0.5
—
Gear roughness
body
0 – 1
0.5
—
Case resonance
clicks
0 – 1
0.5
—
Start/stop clicks
seed
int
1
—
Variation, reproducible
The source is reviewed and run by SonicBricks; agents fetch it as a recipe with sb. It is not published on this page.