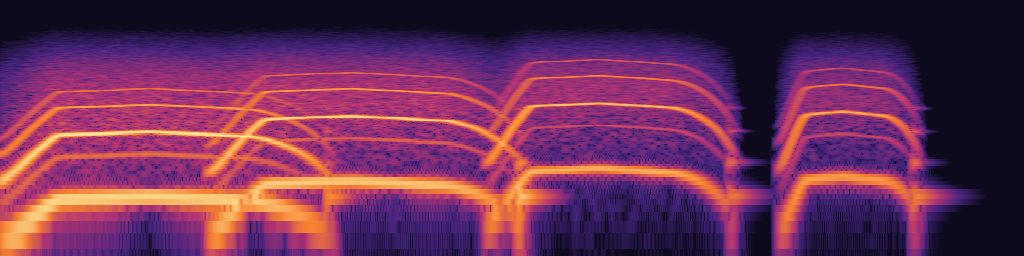
Change parameters to build an exact command. Your agent runs it with sb and gets the WAV.
Command
$ sb get 9QXX7ZJJTR@1 --preset smooth-assembly -o robot-arm-sequence.wav
How it's made
Source
shoulder, elbow and wrist gearmotors execute four coordinated travel segments in about 3 s. Rotor tones at 90–260 Hz support gear-mesh whines at 450–2100 Hz with weaker second/third harmonics.
Motion
each joint accelerates for 70–160 ms, cruises with small load ripple, then brakes over 90–180 ms. Pitch and friction bandwidth follow speed; the wrist makes a short final positioning correction.
Layers
independent filtered bearing noise and 28–65 Hz torque ripple roughen the tonal gear mesh. A low motor winding tone supplies weight without a continuous background motor.
Body
stops excite damped steel housing modes near 155, 370, 810 and 1470 Hz (T60 45–160 ms). A padded contact and a weaker 19 ms delayed backlash tap mark each stop, not explosive impacts.
Envelope
staggered starts and distinct step stops end by 2.65 s at default pace; housing settles naturally before a final 35 ms safety fade. No room reverb is baked in.
Variation
seeded tuning varies by 1.2 percent and stop strengths by 10 percent. Mass lowers tuning, load increases torque ripple and clunks, pace scales travel, and overlap coordinates the joint starts. Presets cover a fast pick-and-place arm, a loaded welder, isolated teaching steps and smooth assembly.
Parameters
Parameter
Range
Default
Unit
Controls
mass
0 – 1
0.55
—
Arm mass
load
0 – 1
0.45
—
Joint load
pace
0.82 – 1.12
1
—
Travel time scale
overlap
0 – 1
0.5
—
Joint overlap
seed
int
1
—
Variation, reproducible
The source is reviewed and run by SonicBricks; agents fetch it as a recipe with sb. It is not published on this page.